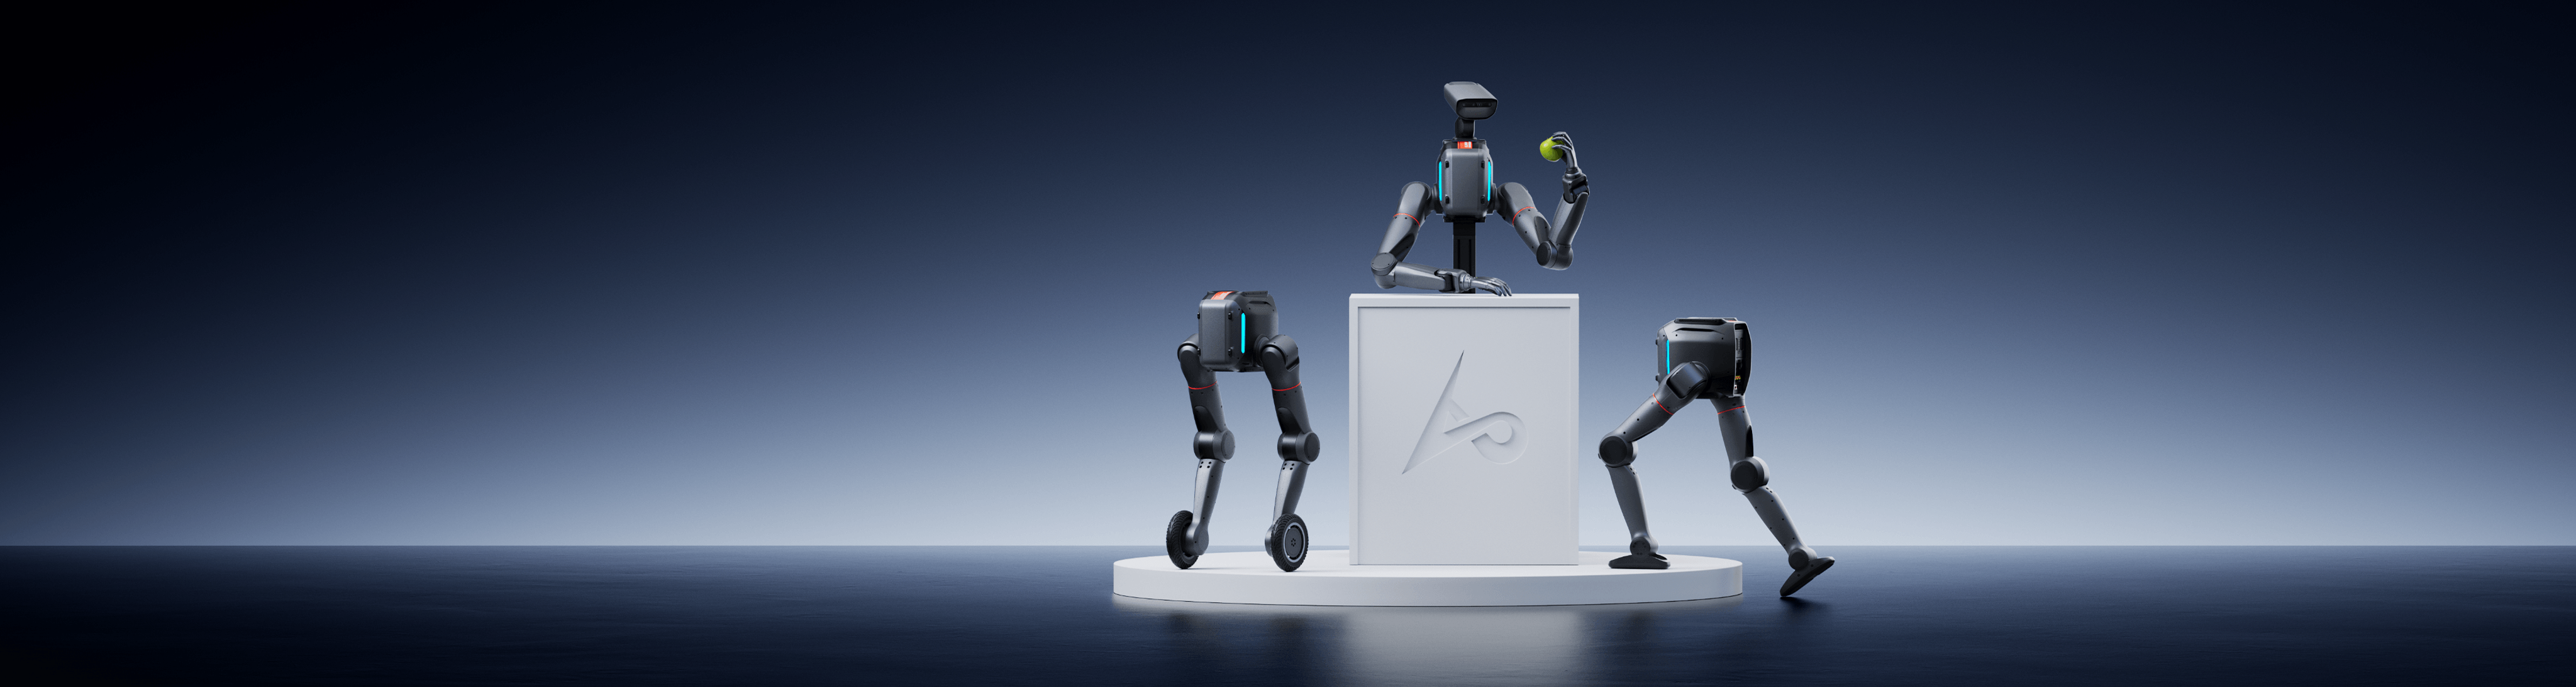
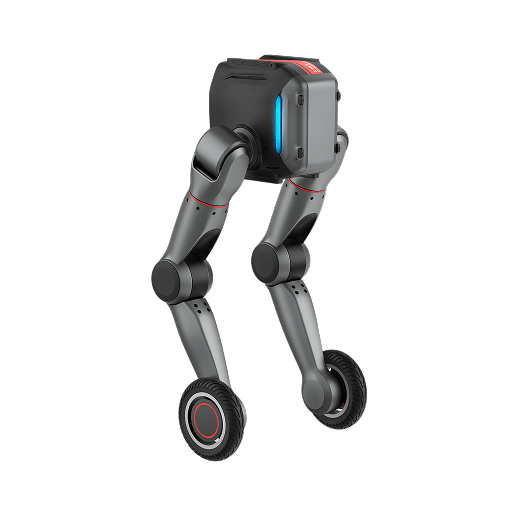
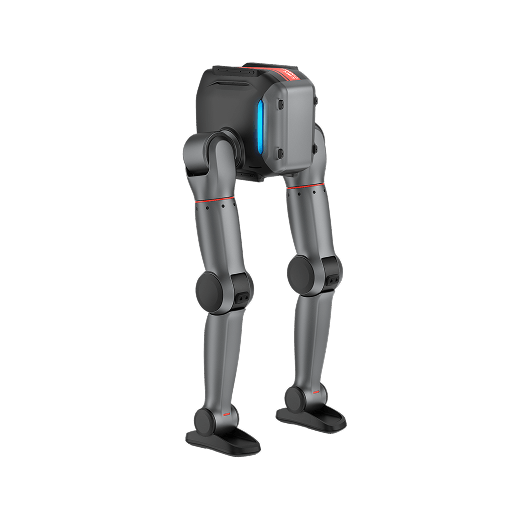
Multi-form embodied robot platform with dual-arm, bipedal and wheeled configurations for mobile manipulation and embodied-intelligence development.
Specifications
| Product model | TRON 2 (Standard / EDU configurations) |
|---|---|
| Degrees of freedom | 7 per arm; 5 per leg; 2 active-vision-head DOF (configuration-dependent) |
| Payload | Dual arms: maximum 5 kg per arm; extended configuration 3 kg per arm; dual-arm headline payload 10 kg |
| Arm payload | 5 kg per arm maximum; 3 kg per arm in extended configuration |
| Reach / workspace | Arm reach 730 mm |
| Walking speed | Sole configuration 2–3 m/s; wheeled configuration 3–5 m/s |
| Maximum climbing slope | Sole configuration 15°; wheeled configuration 30° |
| Maximum step height | 200 mm |
| Maximum battery power | 2800 W |
| Communication interfaces | Ethernet ×1, USB 3.0 ×1, EtherCAT ×2, RS485 ×1 |
| Safety functions | Dual-arm safety-boundary protection; redundant arm power design maintains locked position during power loss |
| Software / SDK | Python and C++; ROS1 / ROS2; open SDK and URDF |
| Technical extension parameters | 46.8 V ternary-lithium battery, 9 Ah; charging 20–80% in 30 min and 20–100% in 54 min; dual arms, bipedal and wheeled configurations; RGB-D and IMU sensor options; Intel Core Ultra; 2 TB storage. Specifications vary by configuration. |
Product images